DIY Arduino Robotic Arm
Personal Project•JUN 2025
Introduction
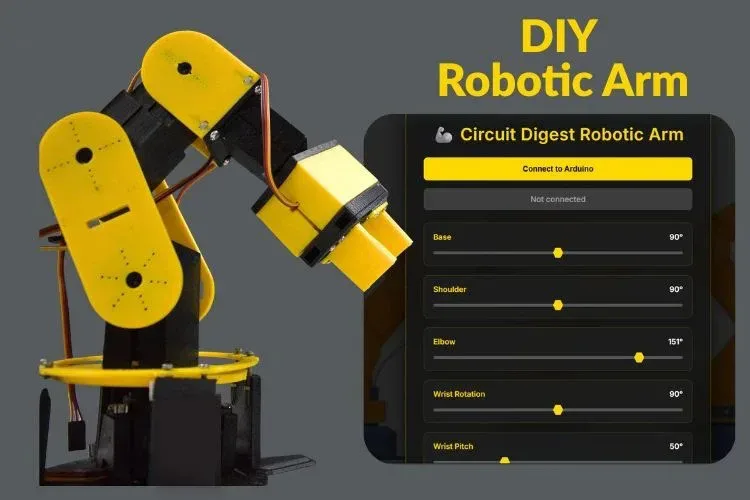
Building a 6-DOF Arduino robotic arm capable of precise pick-and-place operations. Designed for ease of assembly and operation, it includes a complete circuit diagram, Arduino code, and step-by-step instructions. Ideal for learning servo motor control, embedded programming, and the fundamentals of robotics and automation.
Features
• Inverse Kinematics: Calculates precise servo angles for smooth foot positioning.
• Self-Balancing: Uses IMU data to maintain stability on slopes.
• Wireless Control: Operated via a custom mobile app over Bluetooth/WiFi.
• Self-Balancing: Uses IMU data to maintain stability on slopes.
• Wireless Control: Operated via a custom mobile app over Bluetooth/WiFi.
Tech Stack
ControlLoop.cpp
1// Firmware Control Loop (C++)
2void loop() {
3  readSensors();
4  calculateIK();
5  updateServos();
6  delay(10);
7}